Sensors in Humans
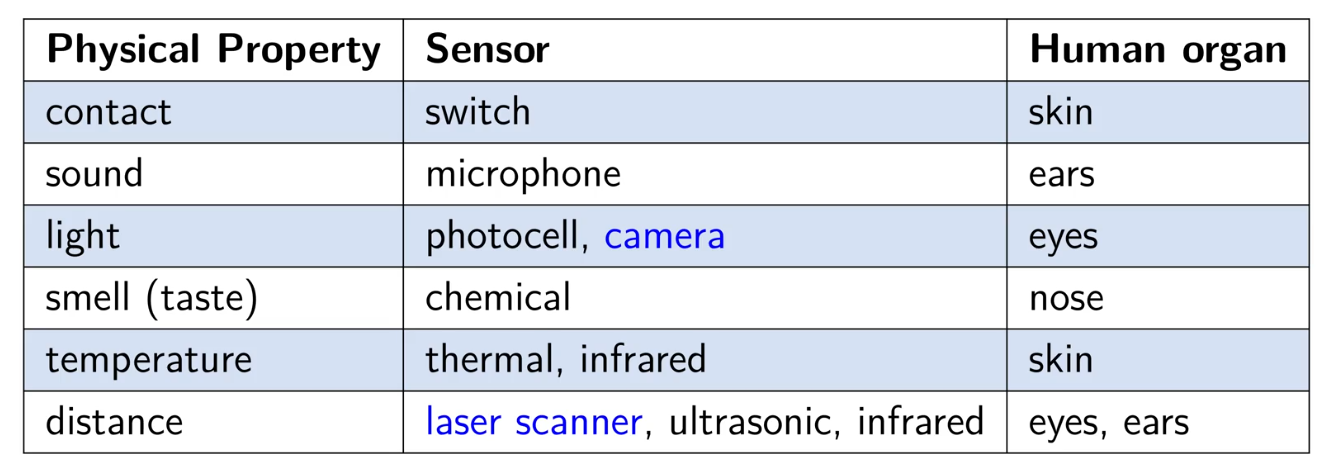
Sensor Types
Interaction with the environment:
- Aktive Sensor => generate stimuli to precive the environment.
- Passive Sensors => react to stimuli from the environment.
Measurement representation:
- Digital sensor => returns binary (on or off)
- Analog sensor => returns continous output signal. eg current
Measured system:
-
Interoceptive sensors - measure internal robot data
(e.g. motor voltage and current, battery state, temperature). -
Proprioceptive sensors - measure robot state in the environment
(e.g. linear and angular position, velocity and acceleration,
forces and torques). -
Exteroceptive sensors - measure the environment directly
(e.g. proximity sensors, camera, pressure).
Sensor Characteristics
- Range => maximum and minimum values
- Sampling Rate => the average number of measurements over time (in Hz)
- Reselution => the smallest ammount that can be detected
- Accuracy => the maximum dkifference between the true value and the measured values
- Quantization Error => the error created by the digitalization of the measurement
Challenges in Robot Sensing
- measurement uncertainties
- deterministic and stochastic noise
- limited measurement frequency I poor resolution
- loss of calibration over time
- sensor failures
- insufficient storage
- multimodal data
Sensor Fusion
Link to original
- Combining multiple sensors to get better information about the world.
- Sensor fusion is a complex process:
- Different modalities.
- Contradictory information.
- Different sampling rates (asynchronous perception).
- Methods: Kalman Filter, Particle Filter, Machine Learning, etc
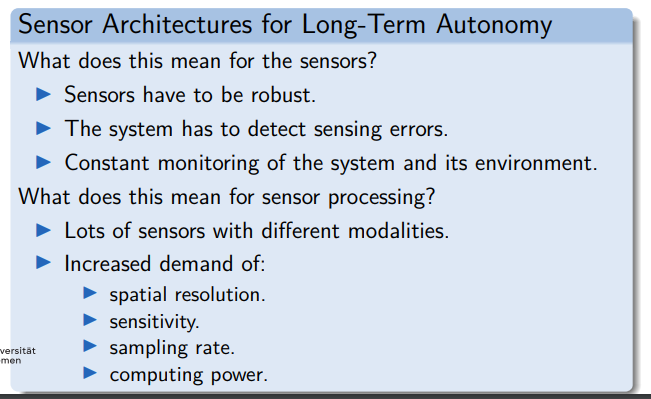
Task: choose Sensores for Drone
Introspective
- Motor current => Self diagnosis
- Motor temperature => Self diagnosis
- Battery charge / consumption => Flight time prediction
Proprioceptive
- Ineratio mesurment units
- Accelerometer => Flight stability
- Gyroscope => Flight stability
- GPS => Broad Navigation
- Barometer => Height Sensor
Exteroceptive
- 3D Lidar poited to the ground. => Lidar SLAM
- Camera => Visual SLAM
- Infrared camera => Search and Assist tasks.
next: RDL VL 04 Odometry