Unicycle Model
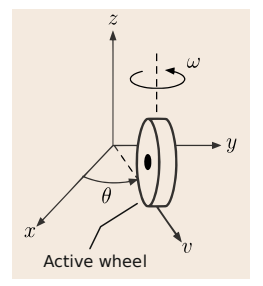
- Composed by a single upright wheel rolling without sideways slip.
- This type of robot is unstable without dynamic control to maintain balance.
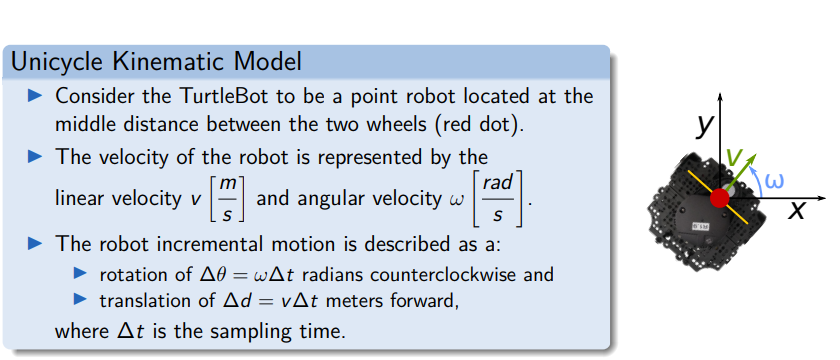
- The robot state is described by its position (x, y) and orientation θ.
- We can control its linear velocity v and angular velocity ω.