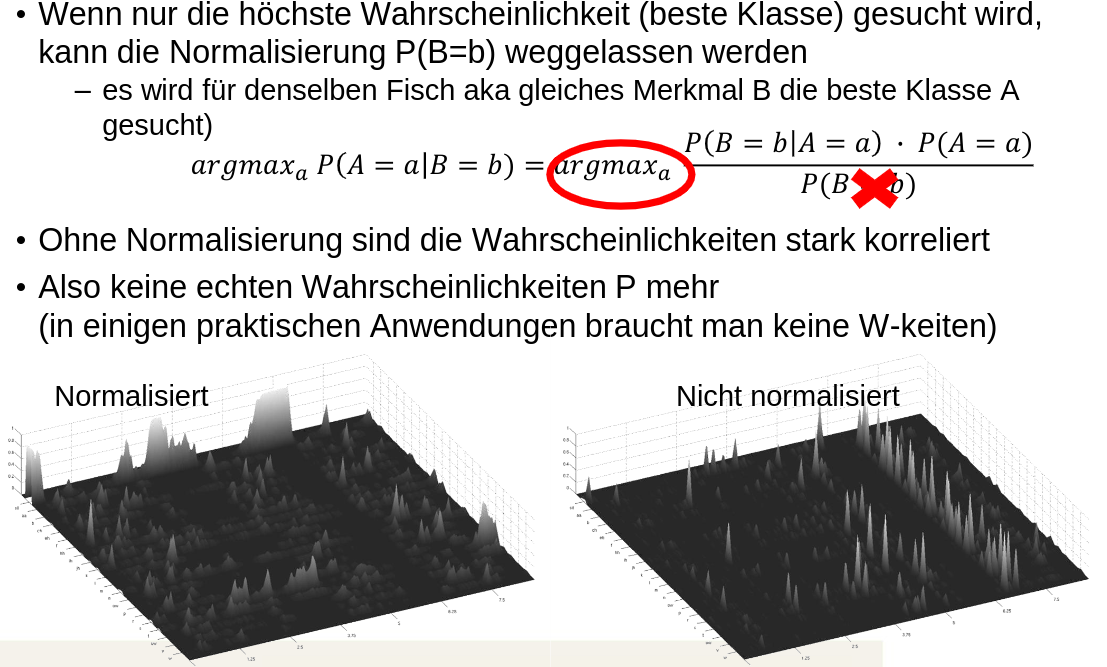
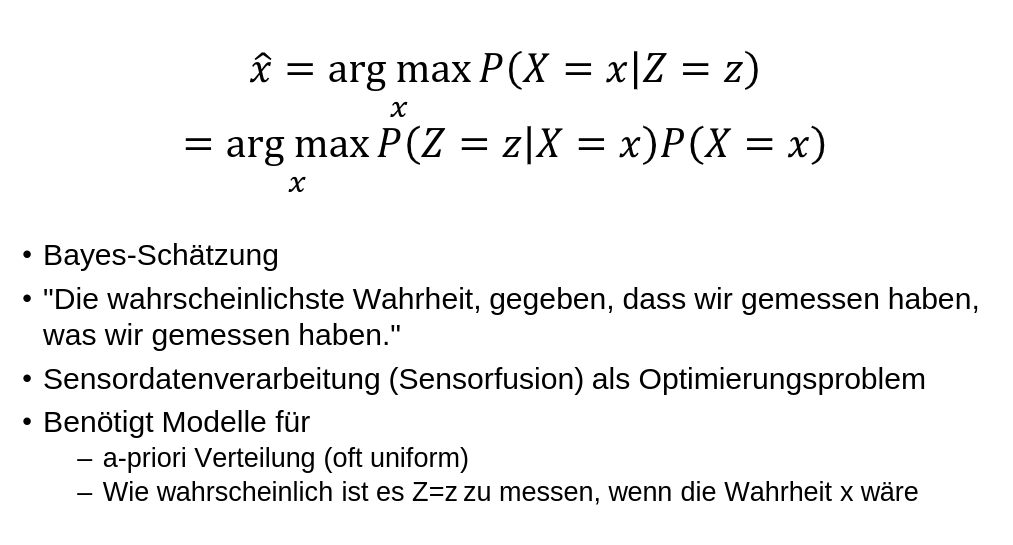
Bayes’ Theorem
=> probability of hypothesis A given data B
(posterior belief distribution)
=> likelihood of data B given hypothesis A
=> independent probability of hypothesis A
(prior belief distribution)
=> independent probability of data B
Example
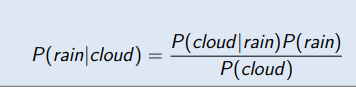
Bayes Filter
Probabilistic method to estimate an unknown probability density function (PDF) recursively over time using incoming sensor measurements and a mathematical process model.
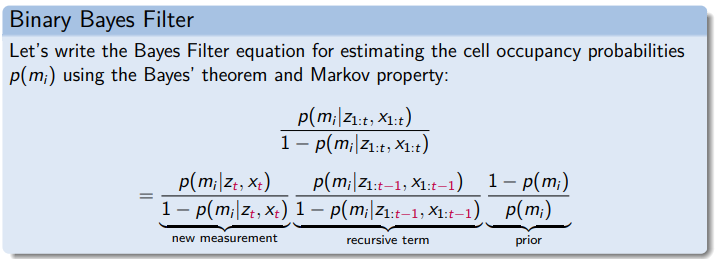
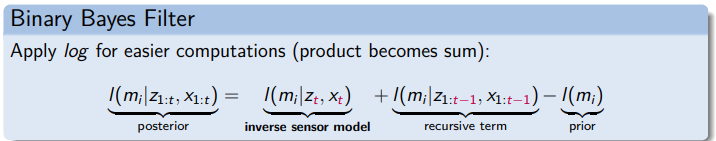
Binary Bayes Filter
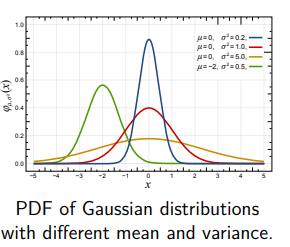
Probability density function (PDF) of a binary variable.
Task
-
Cleaning
-
Resteraunte
-
Security
-
Grid based mapping
Challenges
- Fast Moving Objects
Von Sensor Daten